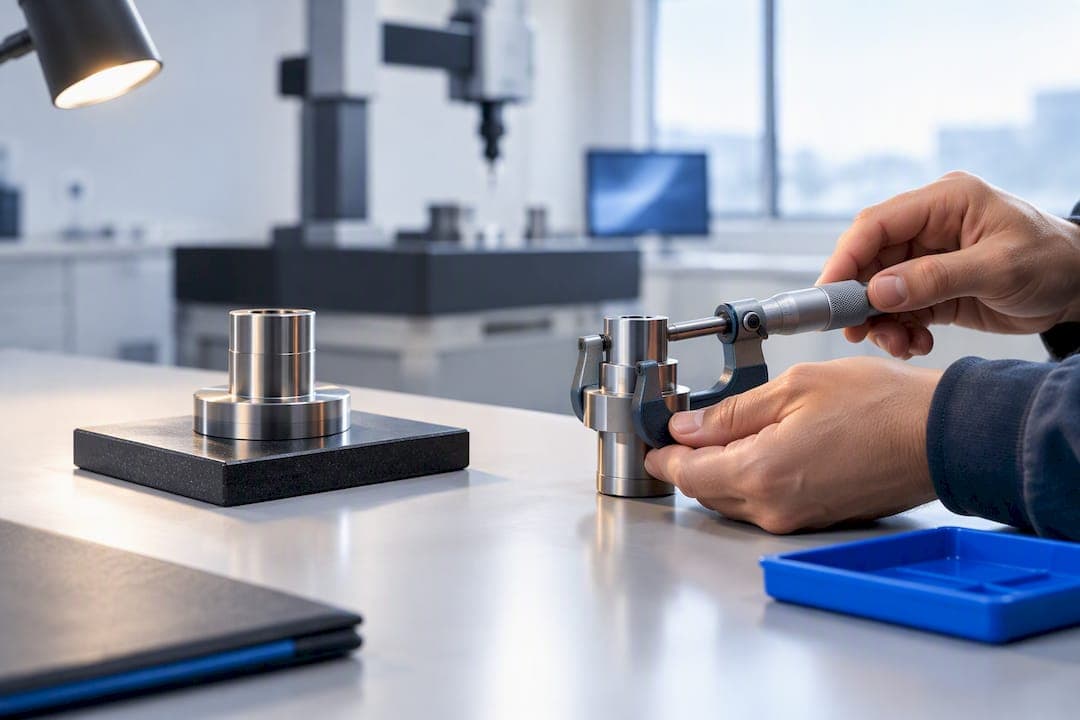
Measurement uncertainty quantifies the range of values that could reasonably be attributed to a measurand, reported as an estimate plus or minus an expanded uncertainty at a stated coverage probability, so you can judge whether a part actually meets its tolerance. It is not the same as measurement error. Understanding measurement uncertainty properly means recognizing that every reading carries a margin of doubt, and that margin must be known before a conformity decision means anything.
TL;DR:
- Measurement uncertainty must account for all significant sources, including environmental conditions, calibration, and operator technique, rather than relying solely on calibration certificates.
- Building an uncertainty budget involves listing inputs, calculating sensitivity coefficients, and combining uncertainties through root-sum-square, with Monte Carlo methods recommended for nonlinear models.
- Guard-banding tightens acceptance limits by considering measurement uncertainty, reducing the risk of wrongly accepting nonconforming parts, especially when calibration uncertainty is included.
- Using repeatability data for Type A evaluation often provides the most cost-effective insight, while documenting assumptions helps maintain a defensible uncertainty estimate.
- Practical measurement workflows leverage software tools to automate uncertainty documentation, flag deviations, and produce audit-ready reports aligned with ISO 9001 and AS9100 requirements.
Table of Contents
- Core definitions: measurand, uncertainty types, and coverage
- A step-by-step workflow for estimating uncertainty
- Building the uncertainty budget: sensitivity coefficients in practice
- Turning uncertainty into pass or fail decisions
- CMM examples and the traps that inflate uncertainty
- Where practitioners should actually start
- Making uncertainty part of your inspection workflow
- Sources
- FAQ
Core definitions: measurand, uncertainty types, and coverage
Before you can estimate uncertainty, you need a shared vocabulary. Quality teams that skip this step tend to argue past each other later, usually during a nonconformance review.
The measurand is the specific quantity you intend to measure, defined precisely enough that two competent inspectors would measure the same thing the same way. A measurement model then expresses how that measurand relates to the inputs you actually observe, such as raw gauge readings, temperature corrections, or calibration offsets. According to the PMC primer on estimating measurement uncertainty, uncertainty is a non-negative parameter describing the dispersion of values that could reasonably be attributed to the measurand, distinct from error, which is the difference between a single measured value and the true value you never fully know.
Reporting follows a consistent pattern. Standard uncertainty (u) describes one component's spread as a standard deviation. Combined standard uncertainty rolls several components into one number. Expanded uncertainty (U) multiplies that combined value by a coverage factor (k) to state a confidence interval, typically written as U = k·u.
- Type A evaluation comes from statistical analysis of repeated observations, such as the standard deviation of ten repeat measurements on the same part.
- Type B evaluation comes from other evidence: calibration certificates, manufacturer specifications, or past experience with a gauge's drift.
- Coverage probability describes how confident you are that the true value falls within your stated range, with k≈2 commonly used for roughly 95% coverage under an assumed Gaussian distribution, per NIST's basic uncertainty definitions.
Both evaluation types feed the same combined uncertainty. Neither is inherently more rigorous than the other; they just draw on different kinds of evidence.
A step-by-step workflow for estimating uncertainty
Estimating uncertainty is less about advanced statistics and more about working through a defined sequence without skipping steps. Here is the order that keeps the process defensible.
- Define the measurand and write a measurement equation. State exactly what you are measuring and how the final result relates to your inputs, including any corrections for temperature, calibration offset, or fixturing.
- Identify every significant uncertainty source. Walk through instrument resolution, environmental conditions, sampling strategy, calibration history, and operator technique, then flag which ones actually matter for this measurement.
- Quantify each component. Use repeat measurements for Type A components and calibration certificates, specification sheets, or documented assumptions for Type B components. A gauge repeatability study might give you a Type A standard deviation of 0.0008 inches, while a calibration certificate supplies a stated Type B uncertainty directly.
- Combine components using the law of propagation of uncertainty. This typically means calculating partial derivatives (sensitivity coefficients) for each input and combining the weighted variances by root-sum-square to get a combined standard uncertainty, as described in the GUM framework summarized by NIST.
- Choose a coverage probability and compute expanded uncertainty. Multiply your combined standard uncertainty by the chosen coverage factor, commonly k=2 for approximately 95% confidence.
For most linear measurement models with roughly Gaussian inputs, that five-step sequence is sufficient. But when your model is strongly nonlinear or an input distribution is far from Gaussian, linearized propagation can understate the real uncertainty. In those cases, GUM Supplement 1 recommends Monte Carlo propagation instead, which simulates the full input distributions numerically and derives the output distribution directly rather than relying on a linear approximation.
Pro Tip: Build your uncertainty budget in a spreadsheet with one row per input source; it turns an abstract calculation into a document you can hand to an auditor.
Building the uncertainty budget: sensitivity coefficients in practice
An uncertainty budget is simply a table that lists every input quantity, its value, its standard uncertainty, its sensitivity coefficient, and its resulting contribution to the combined uncertainty. Laying it out this way forces you to account for every source instead of guessing at a final number.
- List each input quantity with its estimated value and standard uncertainty, whether from repeat measurements or a calibration certificate.
- Compute sensitivity coefficients using partial derivatives of your measurement equation, or approximate them numerically by perturbing one input slightly and observing the change in output.
- Combine contributions by root-sum-square, squaring each input's uncertainty times its sensitivity coefficient, summing the squares, and taking the square root to get the combined standard uncertainty.
- Add covariance terms when inputs are correlated, since ignoring correlation between, say, two measurements taken with the same drifting gauge can understate the true combined uncertainty.
Degrees of freedom matter when your Type A data comes from a small sample. The Welch-Satterthwaite formula estimates effective degrees of freedom for combining components with different confidence levels, but GUM Supplement 1 notes that modern practice increasingly favors Monte Carlo methods over degrees-of-freedom approximations, particularly for nonlinear models.
Turning uncertainty into pass or fail decisions
Uncertainty only matters operationally when it changes what you do with a measurement. A part measuring right at its tolerance limit, with an uncertainty band that straddles that limit, is not clearly conforming or nonconforming. That is where guard-banding comes in.
- Specification limits are not the same as acceptance limits. A guard band shrinks the acceptance zone inside the specification limits by an amount related to measurement uncertainty, so a part is only accepted when its measured value falls safely within the tightened zone.
- Decision rules trade off risk types. A stringent rule guard-bands aggressively to minimize the chance of accepting a bad part, while a relaxed rule accepts more borderline parts to reduce false rejections, and the economics of acceptance rules shows the optimal choice depends on the relative cost of each error type.
- Fixed heuristics like a 4:1 gage-to-tolerance ratio are a starting point, not a substitute for guard-banding, since they ignore the actual measured uncertainty of your process and can be wrong in either direction.
- Calibration uncertainty propagates directly into your pass/fail call, so a gauge's own calibration certificate uncertainty needs to be folded into your combined uncertainty before you set an acceptance limit.
Reading how tolerances are specified and interpreted alongside your uncertainty budget makes the guard-band conversation with engineering much more concrete.
CMM examples and the traps that inflate uncertainty
Coordinate measuring machines are where uncertainty theory meets daily practice, and where its most expensive mistakes tend to happen. According to NISTIR 5170 on CMM measurement uncertainty, sampling strategy, fixturing, and environmental effects such as thermal drift are major contributors, and full mathematical modeling of every error source is often impractical.
- Sampling strategy changes the result. Too few points on a curved surface, or points clustered in one region, can hide real form error and understate uncertainty.
- Control artifacts substitute for a complete model. When a full analytical treatment is too complex, measuring a known reference artifact repeatedly over time gives you a practical estimate of system reproducibility.
- Calibration traceability is necessary but not sufficient. NIST's guidance on metrological traceability is explicit that an unbroken calibration chain must be paired with a stated uncertainty; traceability alone does not confirm fitness for purpose.
- Under-sampling and ignored sensitivity are the most common pitfalls, along with treating a calibration certificate as the whole uncertainty story instead of one input among several.
Documenting your assumptions, using control artifacts consistently, and running Monte Carlo simulation for genuinely complex models are the practical remedies that keep a CMM uncertainty budget honest over time.
Where practitioners should actually start
Teams new to uncertainty analysis often reach for the most complex propagation method first, then stall. A better sequence is to nail down the measurand definition and build a minimal, defensible budget before attempting anything elaborate.

Collect repeatability data early, since it is usually the cheapest evidence you can gather and it often dominates the combined uncertainty anyway. Where repeat measurements are not practical, document your Type B assumptions and their source honestly rather than guessing at a number that looks tidy.
From there, iterate. Improving a sampling plan or tightening a guard band typically returns more than chasing a marginal improvement in a single formula.
— Michael Chen
Making uncertainty part of your inspection workflow
Calculating uncertainty by hand for every characteristic on a complex part is not realistic for most shops, which is exactly the gap an inspection platform is built to close. QA-Report's measurement wizard links ballooned drawing dimensions to measured results, imports CMM inspection data directly, and auto-flags out-of-tolerance deviations against the tolerance you specify.
In practice, that means capturing measurement data as it comes off the CMM or hand gauge, attaching calibration certificate references to the readings that depend on them, and generating an audit-ready report that documents your process alongside the statistical summary. It will not replace the metrology behind your uncertainty budget, but it removes the manual assembly work of turning that budget into a report that satisfies ISO 9001 or AS9100 auditors. Plans start at the QA-Report pricing page, including a Free tier for teams who want to try the workflow before committing.
Sources
- Basics of Estimating Measurement Uncertainty (PMC)
- Basic definitions of uncertainty (NIST)
- Evaluation of measurement data — Supplement 1 to the GUM (Monte Carlo)
- Measurement uncertainty considerations for coordinate measuring machines (NISTIR 5170)
FAQ
How do you measure the uncertainty of a measurement?
You identify every significant source of variation, from instrument resolution to calibration and environmental effects, then quantify each as a standard uncertainty using repeated measurements or best-available evidence. Those components are combined by root-sum-square into a combined standard uncertainty, then multiplied by a coverage factor to get the expanded uncertainty, as described in the GUM framework.
What is uncertainty in measurement in simple words?
Measurement uncertainty is a way of saying how much doubt surrounds a measured value, expressed as a range rather than a single number. It reflects everything that could cause your reading to differ from the true value, from the gauge's own precision to how carefully the part was held.
What are the four types of uncertainty?
There is no single universal list of exactly four uncertainty types; the GUM framework itself defines two evaluation methods, Type A and Type B, based on how the evidence was gathered. Some engineering references group sources into four practical categories such as instrument, environmental, procedural, and calibration uncertainty, but these fall under the same Type A or Type B classification once quantified.
What are the rules for calculating uncertainties?
Standard uncertainties from independent sources are combined by root-sum-square, weighted by each input's sensitivity coefficient, to produce a combined standard uncertainty. That combined value is then multiplied by a coverage factor, often k≈2 for about 95% coverage, to report an expanded uncertainty, per NIST's uncertainty guidance.